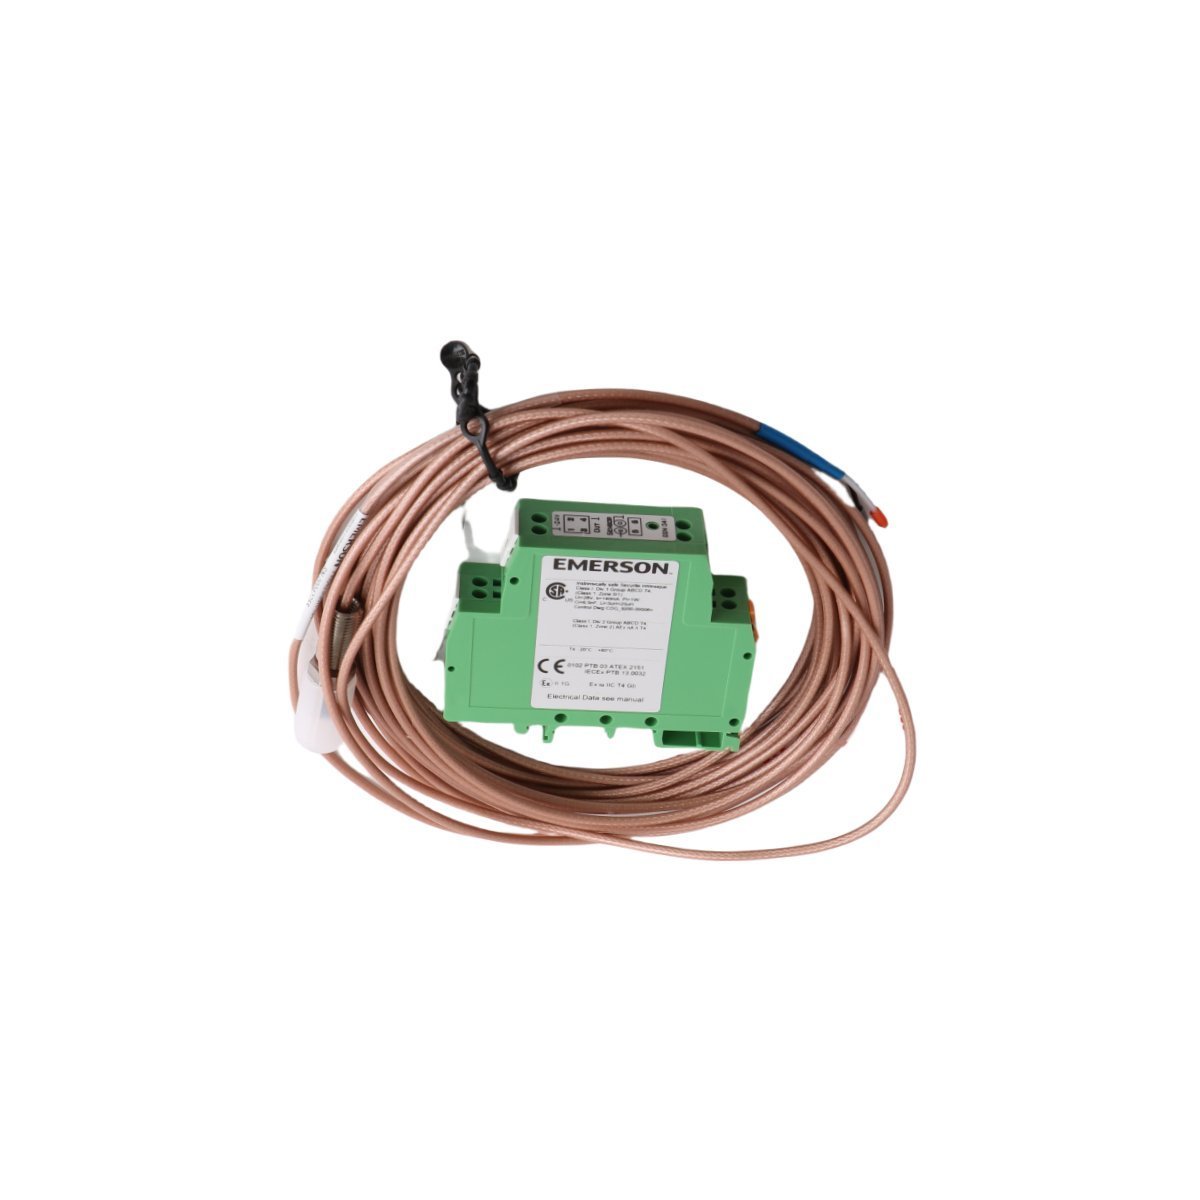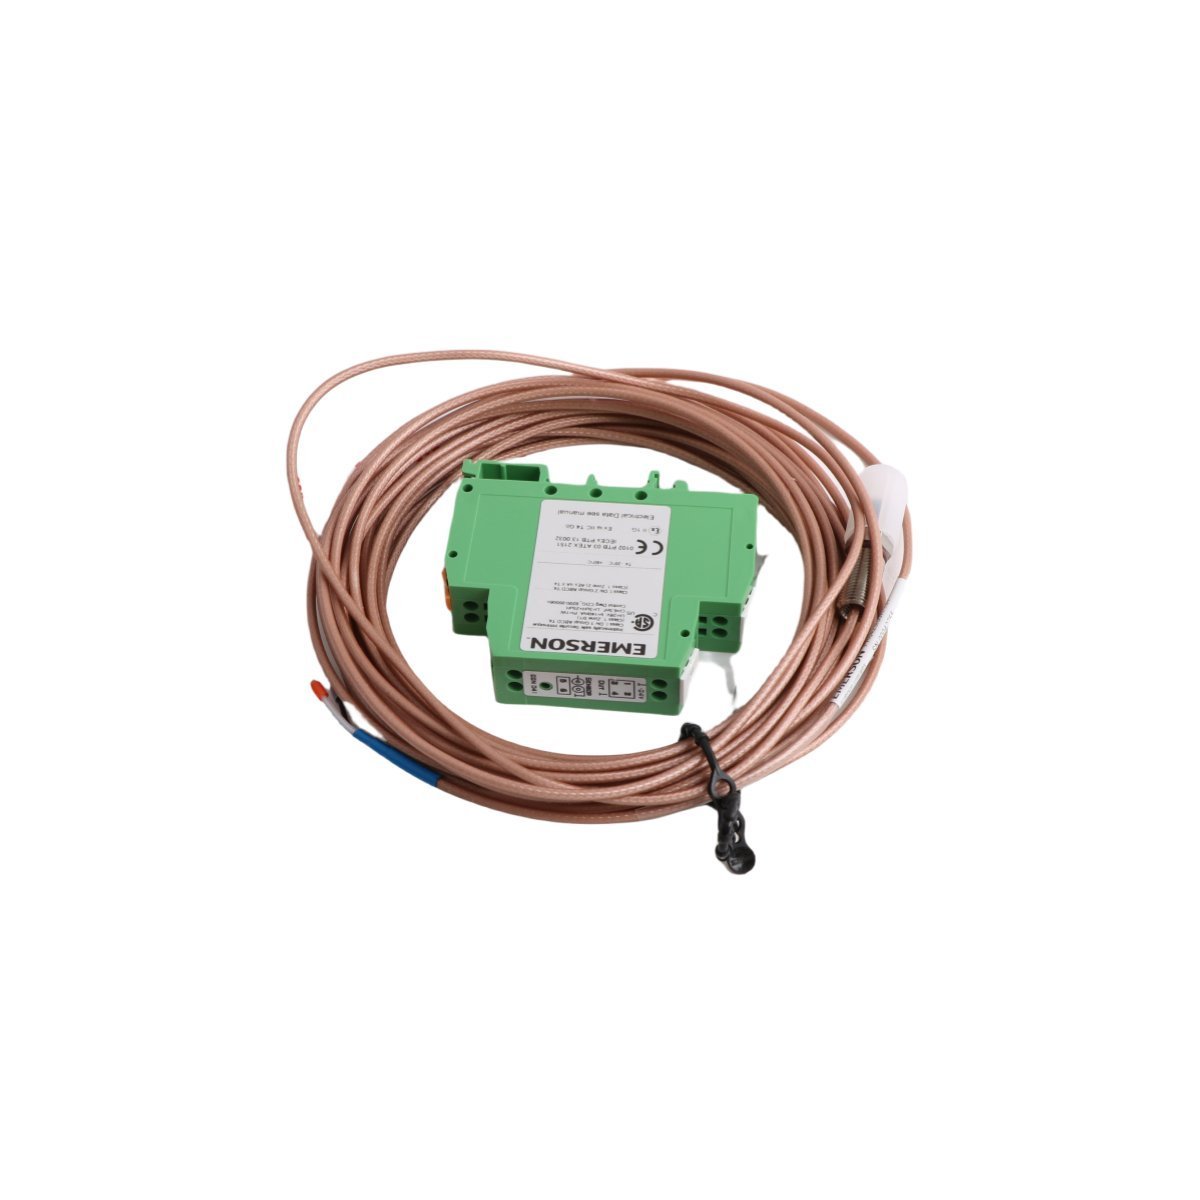
Factory original Bently Nevada 330881-28-05-114-03-02 PROXPAC XL Proximity Transducer Assembly in stock. Secure original equipment hardware for industrial turbine supervisory instrumentation systems with global shipping options. Request technical quotes.
The Bently Nevada 330881-28-05-114-03-02, also cataloged as the Bently Nevada 330881 PROXPAC XL Proximity Transducer Assembly, operates as a dedicated hardware component for eddy-current proximity probe packaging and environmental protection within TSI (Turbine Supervisory Instrumentation) systems.
Hardware Specifications
Parameter
Specification
Model
330881-28-05-114-03-02
Brand
Bently Nevada
Origin
USA
Weight
1.44 kg
Dimensions
30.02 x 12.00 x 9.14 cm
Operating Temp
-35 to +85 deg C
Power Consumption
Passive mechanical housing / probe dependent
System Compatibility
Bently Nevada 3500 Series TSI
Enclosure Rating
IP66 / Type 4X equivalent
Proximity Transducer System Integration
The PROXPAC XL housing ensures rigid mechanical installation and structural alignment for proximity probes. It maintains steady positioning to ensure proper eddy-current probe scaling and loop verification. Field calibration processes rely on precise mechanical adjustment to align the internal gap voltage validation (-10 VDC targets) within the linear range of the corresponding Proximitor Sensor.
The structural design isolates the internal sensor wiring from external noise, contributing to cross-talk suppression between adjacent transducer paths deployed across high-density rotor dynamics monitoring locations.
Frequently Asked Questions
Q: What is the primary purpose of the PROXPAC XL assembly housing?
A: It provides environmental protection and a rigid mechanical mounting structure for proximity probes used in continuous machinery vibration and gap measurement installations.
Q: How is the gap voltage validated within this assembly?
A: Gap voltage must be verified using a digital multimeter connected to the Proximitor Sensor outputs, adjusting the mechanical depth of the probe within the assembly to hit the target voltage, typically -10 VDC for standard linear ranges.
Field Installation Guidelines
Ensure the target surface area meets the minimum diameter requirements defined by the specific probe tip size to prevent side-viewing or cross-talk interference.
Maintain clean threads and execute standard mechanical engagement guidelines during internal housing depth adjustments.
Route all coaxial extension cables through flexible or rigid conduit paths to prevent structural chafing and electromagnetic noise injection.
Connect cable shields to the designated instrumentation isolation ground at the monitor rack panel end only; do not ground shields at both ends.
Configured for high-speed motion synchronization in ControlLogix systems, the Allen-Bradley 1756-M16SE (1756-M16SE SERCOS interface Module) provides direct physical and electrical execution for multi-axis servo drive command distribution.
Hardware Specifications
Parameter
Specification
Model
1756-M16SE
Brand
Allen-Bradley
Origin
USA
Weight
0.22 kg
Dimensions
3.5 cm x 14 cm x 14.5 cm
Operating Temp
Standard industrial range
Power Consumption
Backplane dependent
Data Rate
4 Mbps or 8 Mbps
Axis Capacity
16 axes per module
PLC Control and Communication Characteristics
The 1756-M16SE utilizes high-speed backplane bus communication velocity to manage deterministic data exchange between the ControlLogix CPU and remote servo drive nodes. By leveraging digital fiber-optic SERCOS interfaces, the module achieves I/O density scaling that minimizes signal propagation latency across 16 managed axes. Furthermore, the module supports firmware flash compatibility, which allows for site-specific motion algorithm updates without physical hardware replacement. This deterministic network structure ensures that position, velocity, and torque command loops maintain sub-millisecond synchronization even in high-density drive configurations.
Frequently Asked Questions (FAQ)
Q: What are the primary limitations when configuring the SERCOS ring topology for the 1756-M16SE?A: The ring topology is limited by the physical length of the fiber-optic cabling and the total number of connected nodes; you must ensure the total loop latency does not exceed the configured cycle time (0.5 ms or 1.0 ms) to maintain deterministic operation.Q: Is the 1756-M16SE module capable of hot-swapping within an active ControlLogix chassis?A: The module supports standard ControlLogix hot-swap procedures; however, removing the module will immediately drop the SERCOS ring communication, causing all connected servo drives to transition to their programmed fault state.
Field Installation Guidelines
To begin with, confirm the ControlLogix chassis backplane is powered down; subsequently, insert the 1756-M16SE into a designated slot and secure it using the integrated module locking screws to ensure proper backplane contact.
In addition, route the SERCOS fiber-optic cables following the ring or linear topology requirements;Â meanwhile, maintain the minimum bend radius of the fiber to prevent micro-fractures that induce signal loss.
Furthermore, ensure all fiber-optic connectors are clean and free of contaminants before insertion into the module transceivers;Â consequently, this prevents optical attenuation that could lead to intermittent link failures.
Finally, configure the module addressing and axis scaling within the control software;Â by doing so, you ensure the controller can successfully establish the SERCOS communication cycle with the downstream Kinetix drives.
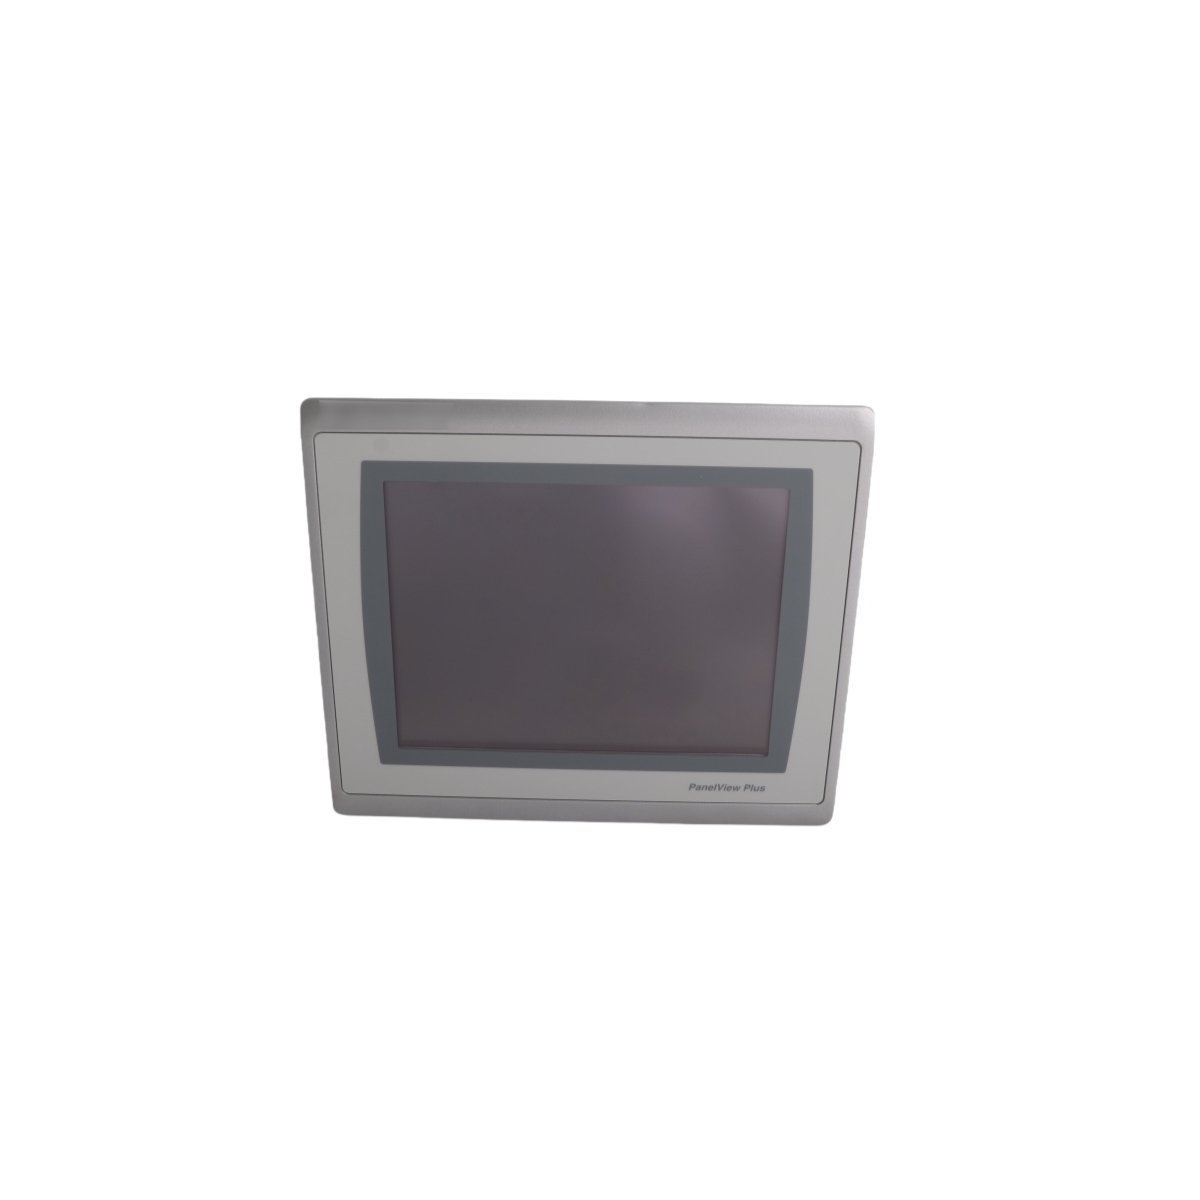
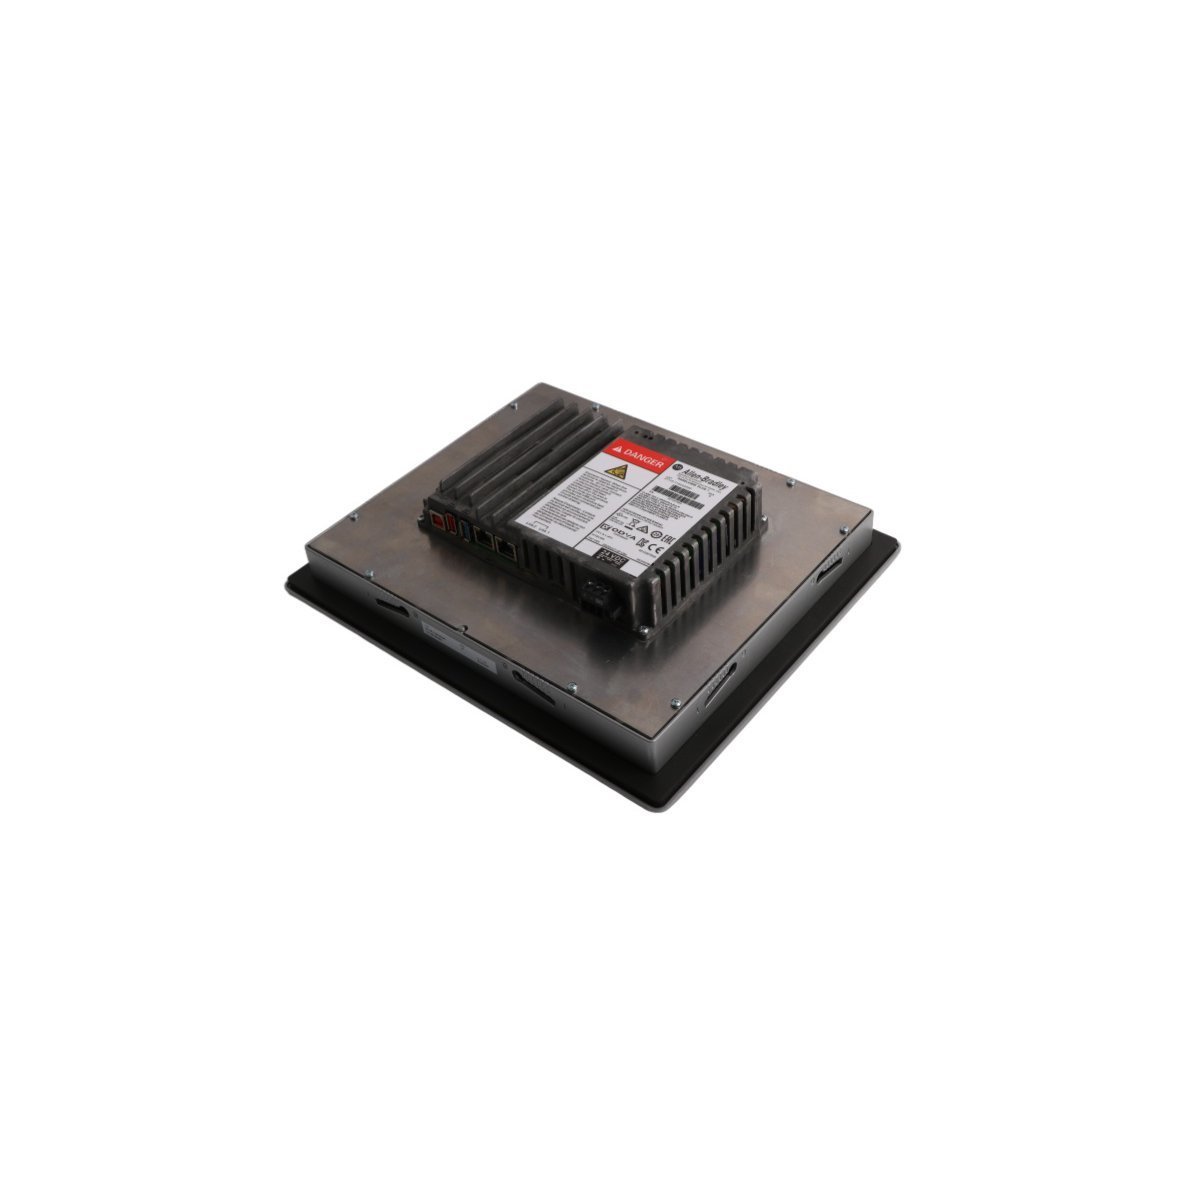
Purchase the Allen-Bradley 2711P-T12W22D9P-B SER B operator interface featuring a 12.1-inch widescreen display and dual DLR Ethernet ports. Brand New, Original Stock with Global Shipping. Secure industrial runtime performance now.
The Allen-Bradley 2711P-T10C22D9P serves as the primary 2711P-T10C22D9P PanelView Plus 7 Standard Color Terminal utilized to execute human-machine interface (HMI) visualization tasks across ControlLogix and CompactLogix platforms. Configured for direct panel monitoring and physical touch input control, the unit provides real-time graphic execution of process variables over local network nodes.
Hardware Specifications
Parameter
Specification
Model
2711P-T10C22D9P
Brand
Allen-Bradley / Rockwell Automation
Origin
USA
Weight
0.9 kg (Net) / 2.3 kg (Packaged)
Dimensions
3.5 x 13 x 14.5 cm (Chassis depth/profile variation)
Operating Temp
0 to +55 deg C
Power Input
24 VDC (PELV/SELV compliant)
Power Consumption
50 W maximum
Display Type
10.4-inch Color TFT (800 x 600 SVGA)
Memory
512 MB RAM / 80 MB Non-volatile user storage
Communication Ports
Dual 10/100 Base-T Ethernet (DLR), USB ports
Discontinued Date
June 30, 2016 (Catalog data reference)
Deterministic Network Routing & I/O Density Scaling
The HMI assembly utilizes integrated dual Ethernet ports configured for Profinet / EtherNet/IP deterministic networks, supporting Device Level Ring (DLR), linear, and star network topologies directly at the machine layer. This eliminates the necessity for external switches while protecting communication velocity against single-point physical cable breaks.Internal memory constraints control runtime graphic caching, allowing scaling for dense register structures mapped from local programmable automation controllers. Device settings and operational runtime parameters are updated via standard firmware flash compatibility tools or through FactoryTalk View Studio Machine Edition configuration routines.
Frequently Asked Questions
Q: What are the dual Ethernet port operational constraints regarding separate IP subnets?A: The integrated dual ports function as an embedded switch node supporting Device Level Ring (DLR) topology. Both physical interfaces share a single IP address and cannot be partitioned to bridge separate, independent subnets.Q: How is application data retention managed if primary 24 VDC input power is lost?A: The terminal utilizes onboard non-volatile flash memory to store the compiled runtime (.mer) application project file. System parameters and historical log data are committed directly to internal solid-state registers, removing battery dependency for file preservation.
Field Installation Guidelines
Enclosure Cutout Positioning: Prepare the panel door cutout using exact engineering template metrics. Ensure the surrounding sheet metal remains flat and free of distortion to establish uniform compression against the sealing gasket.
Torque Adjustments for Mounting Clips: Tighten the supplied panel mounting levers evenly in an alternating sequence. Do not exceed specified torque limits to avoid cracking the plastic bezel or compromise the NEMA/IP environmental seal.
Grounding Requirements: Connect the functional earth terminal on the rear power input connector block to a low-impedance master enclosure ground bar using a dedicated, short copper wire.
External Storage Handling: Insert or extract approved external memory cards only when the execution engine is idle to prevent database structure corruption within historical trending folders.
The Allen-Bradley 1756-TBNH is a heavy-duty 20-pin NEMA screw-clamp removable terminal block for ControlLogix I/O field installations. Genuine factory original units are in stock now with expedited worldwide delivery options. Safeguard your automation uptime and wiring integrity today.
The EMERSON PR6423/00R-131 CON041 is a factory-original eddy current signal converter designed for high-accuracy displacement monitoring. Acquire this brand new, original stock component with secure worldwide shipping options and guaranteed hardware verification. Contact our technical team today to finalize your industrial replacement requirements.
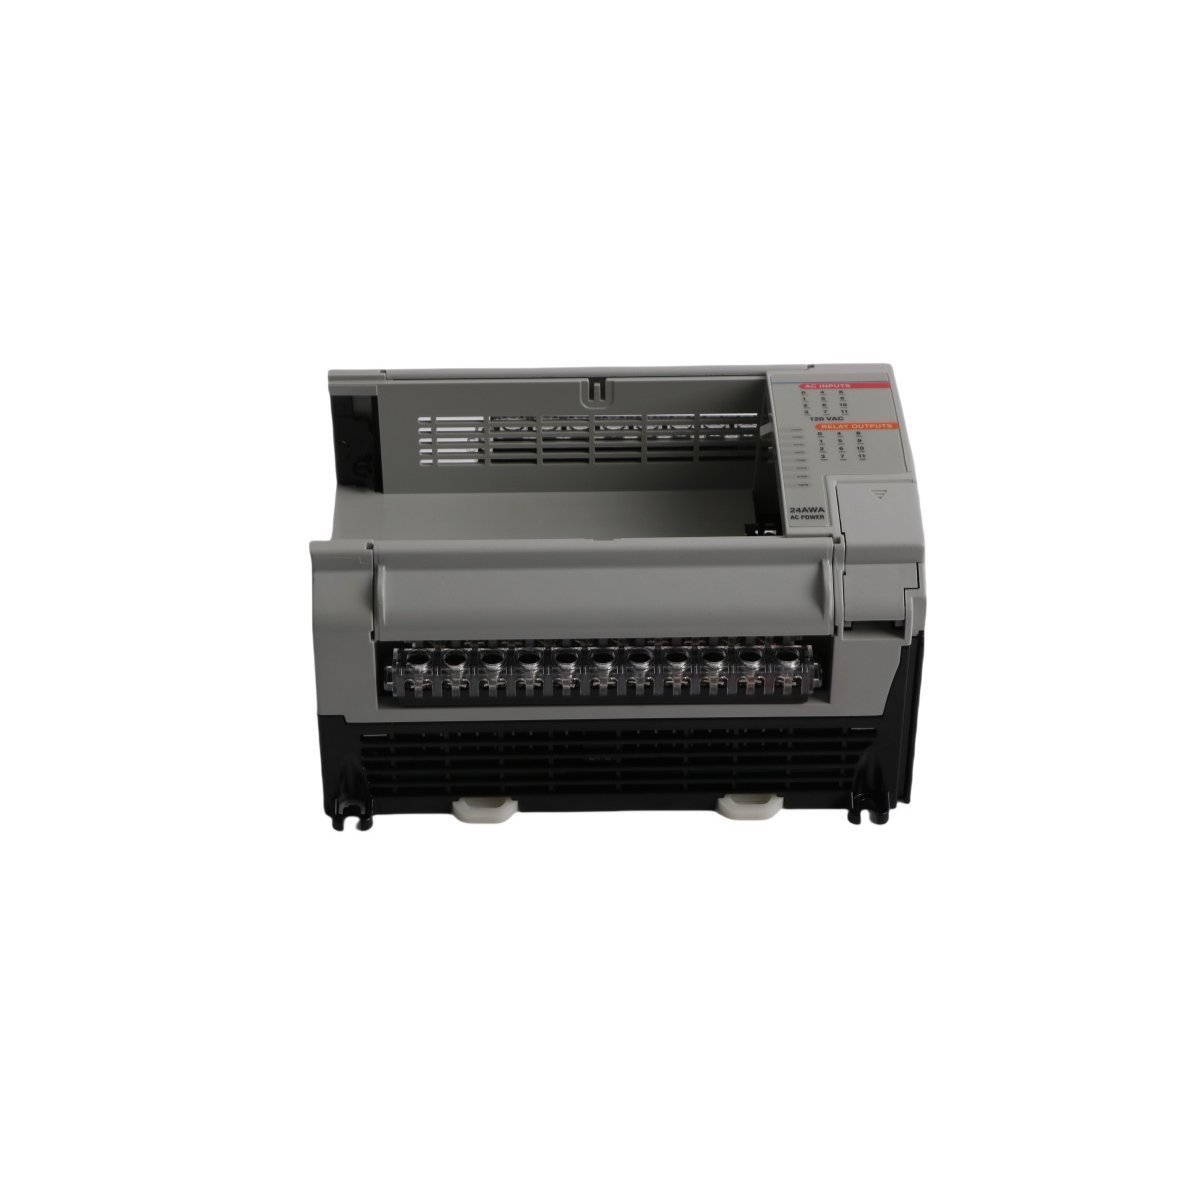
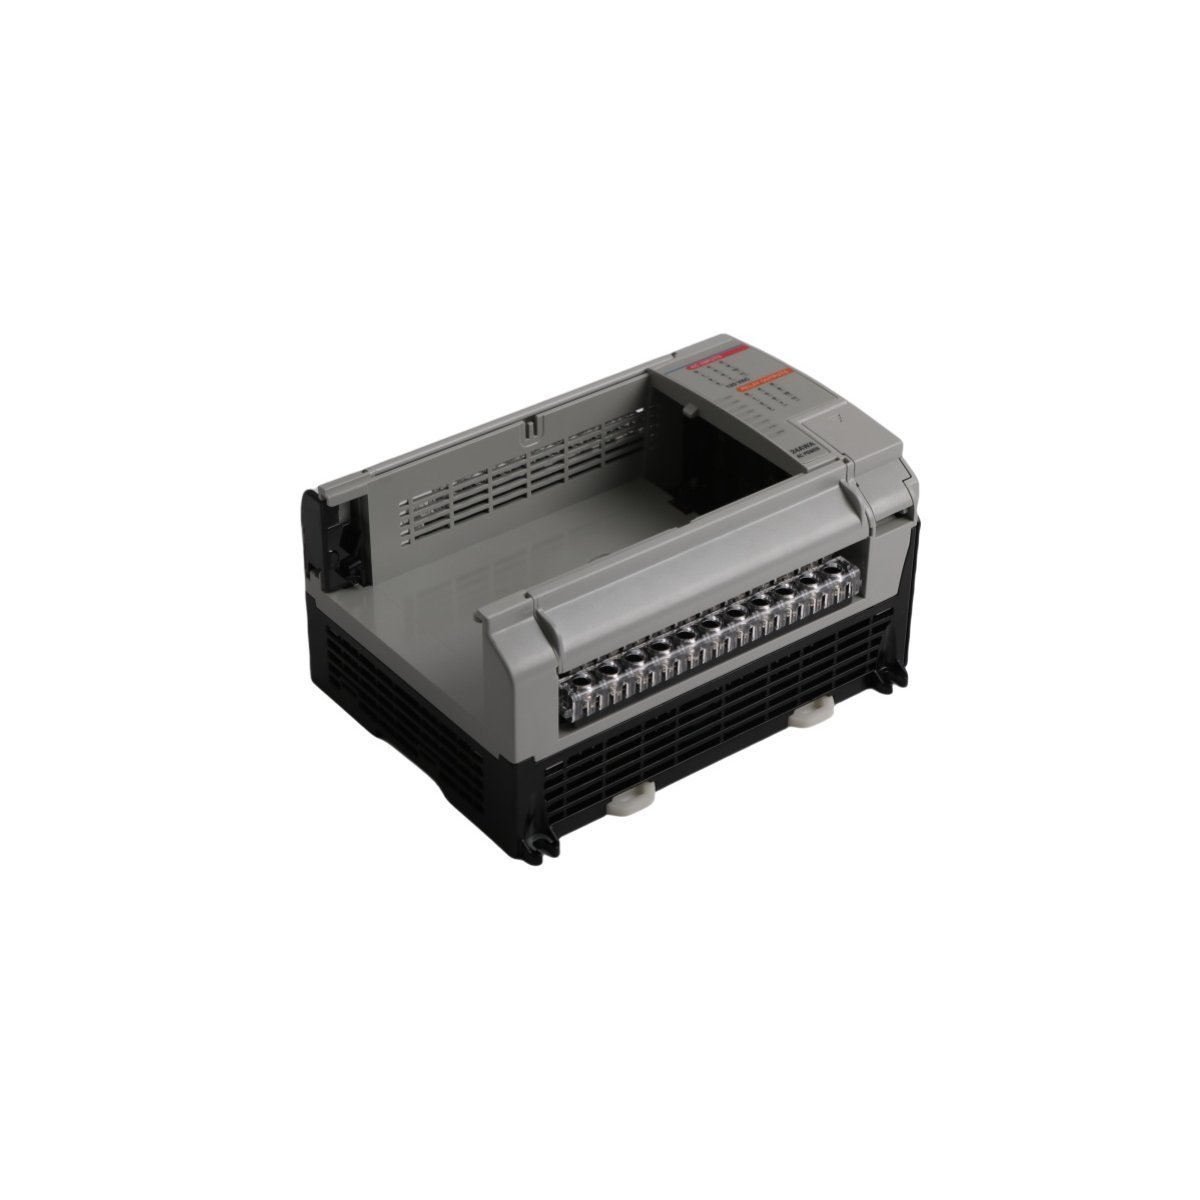
The Allen-Bradley 1764-24AWA is a 120 VAC powered MicroLogix 1500 PLC base unit featuring 12 embedded AC inputs and 12 relay outputs. Brand new factory-sealed units are ready for industrial machinery deployments with fast worldwide shipping. Keep your legacy control panels running efficiently.
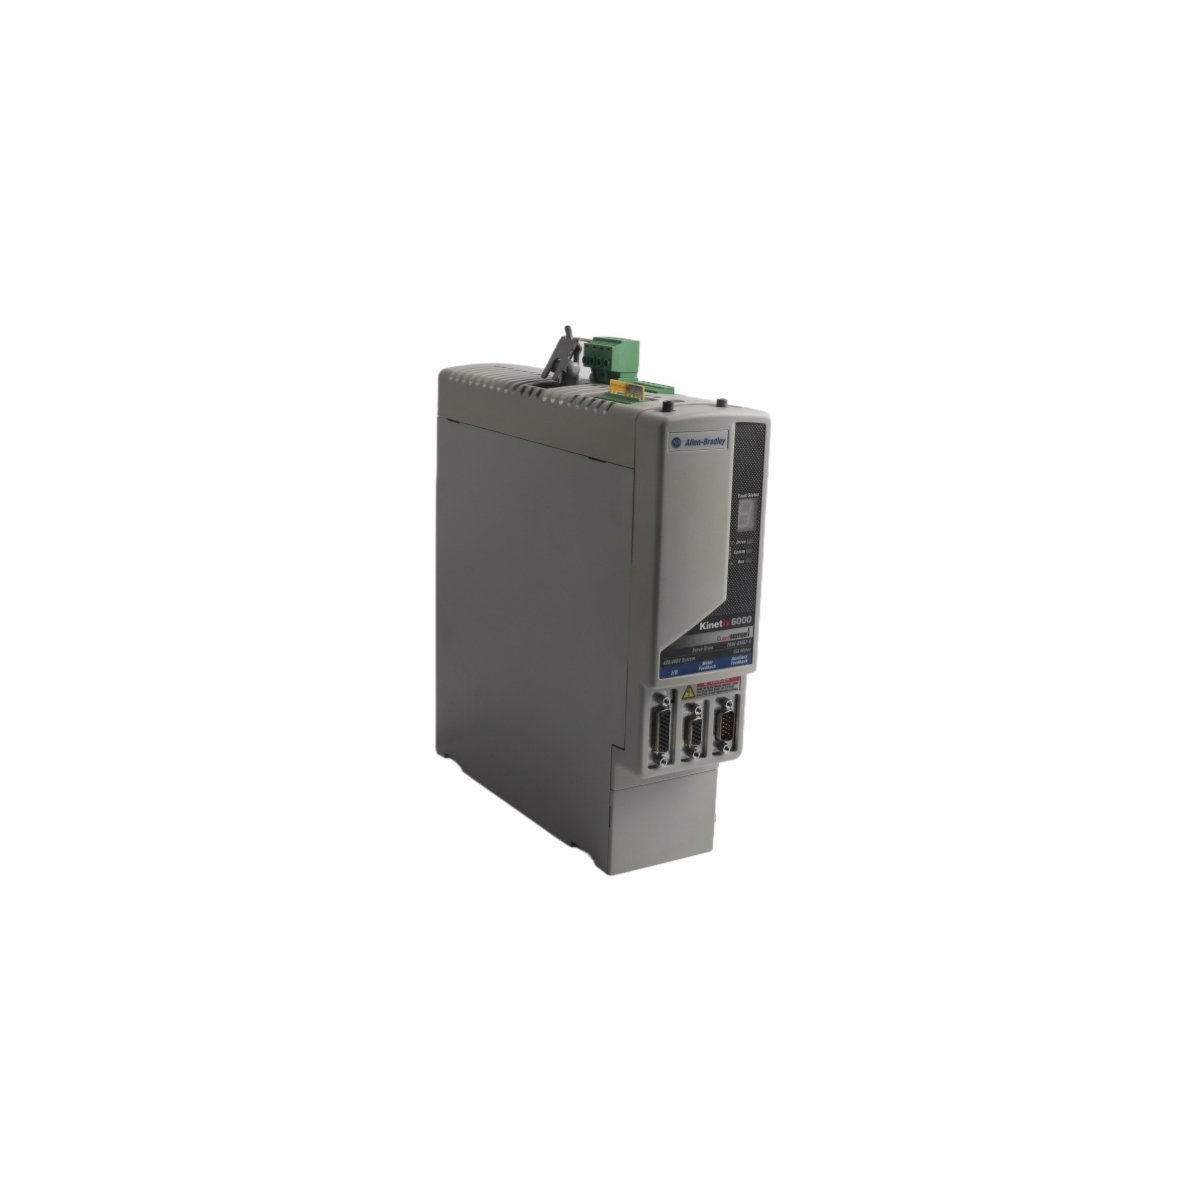
The Allen-Bradley 2094-BM02-S, also cataloged as the 2094-BM02-S Servo Drive, operates as a dedicated hardware component for multi-axis motion control execution within ControlLogix platforms. The hardware acts as a modular inverter node mounted directly onto a shared integrated power rail system. It modulates raw DC link energy into high-frequency pulse-width modulation (PWM) power vectors to regulate the angular positioning, velocity, and torque outputs of synchronized permanent magnet synchronous motors.
Industrial Control & Deterministic Driving Network
The Allen-Bradley 2094-BM02-S interacts directly over backplane bus communication velocity networks to achieve microsecond-level synchronization across adjacent drive modules. The hardware features deterministic network compatibility, letting control processors command motion trajectories with minimal jitter. It supports peak enhancement technology, scaling the nominal inverter output profile from a standard 150% threshold up to 250% during peak torque demands. This scaling permits rapid rotor acceleration and deceleration profiles without triggering overcurrent trips. Integrated Safe-Torque Off (STO) hardware circuits provide independent physical galvanic control paths, disabling gating signals to the output power transistors to prevent unexpected motor rotation during active maintenance states.
Frequently Asked Questions
Q: What are the backplane current and configuration limits when expanding axis modules on a single rail?A: The module must be inserted into an authorized Kinetix 6000 power rail, supporting up to seven axis modules alongside one master power module. The cumulative peak current draw must not exceed the structural rating of the shared copper backplane link.Q: Is this hardware compatible with live hot-swapping procedures?A: No. The shared 650 VDC bus lines pose arc-flash and component damage hazards. System DC bus voltage must be entirely drained and verified below safe thresholds before seating or unseating the module from the rail structure.Q: Can the internal 115 Ohm shunt resistor handle high-inertia braking loads?A: The internal shunt resistor is designed for short-duration thermal dissipation. High-inertia or cyclic deceleration applications require an external, isolated shunt module to prevent DC bus overvoltage faults.
Field Installation Guidelines
Enclosure Clearance & Thermal Profile: Maintain a minimum enclosure installation depth of 10.7 inches. Ensure unimpeded vertical ventilation spacing above and below the module chassis to prevent heat sink thermal saturation.
Cable Separation Architecture: Physically isolate unshielded high-voltage power cables, including motor leads and shunt resistor lines, from low-level digital feedback encoder loops and communication wires to suppress cross-talk.
Shielding and Ground Boundary: Terminate all motor cable shields at the designated grounding clamp on the power rail base. Maintain a low-impedance ground plane across the entire mounting subpanel.
Overcurrent Protection: Install specified circuit breakers or high-speed semiconductor fuses upstream of the main power distribution block to guard the internal solid-state components against phase-to-phase short circuits.
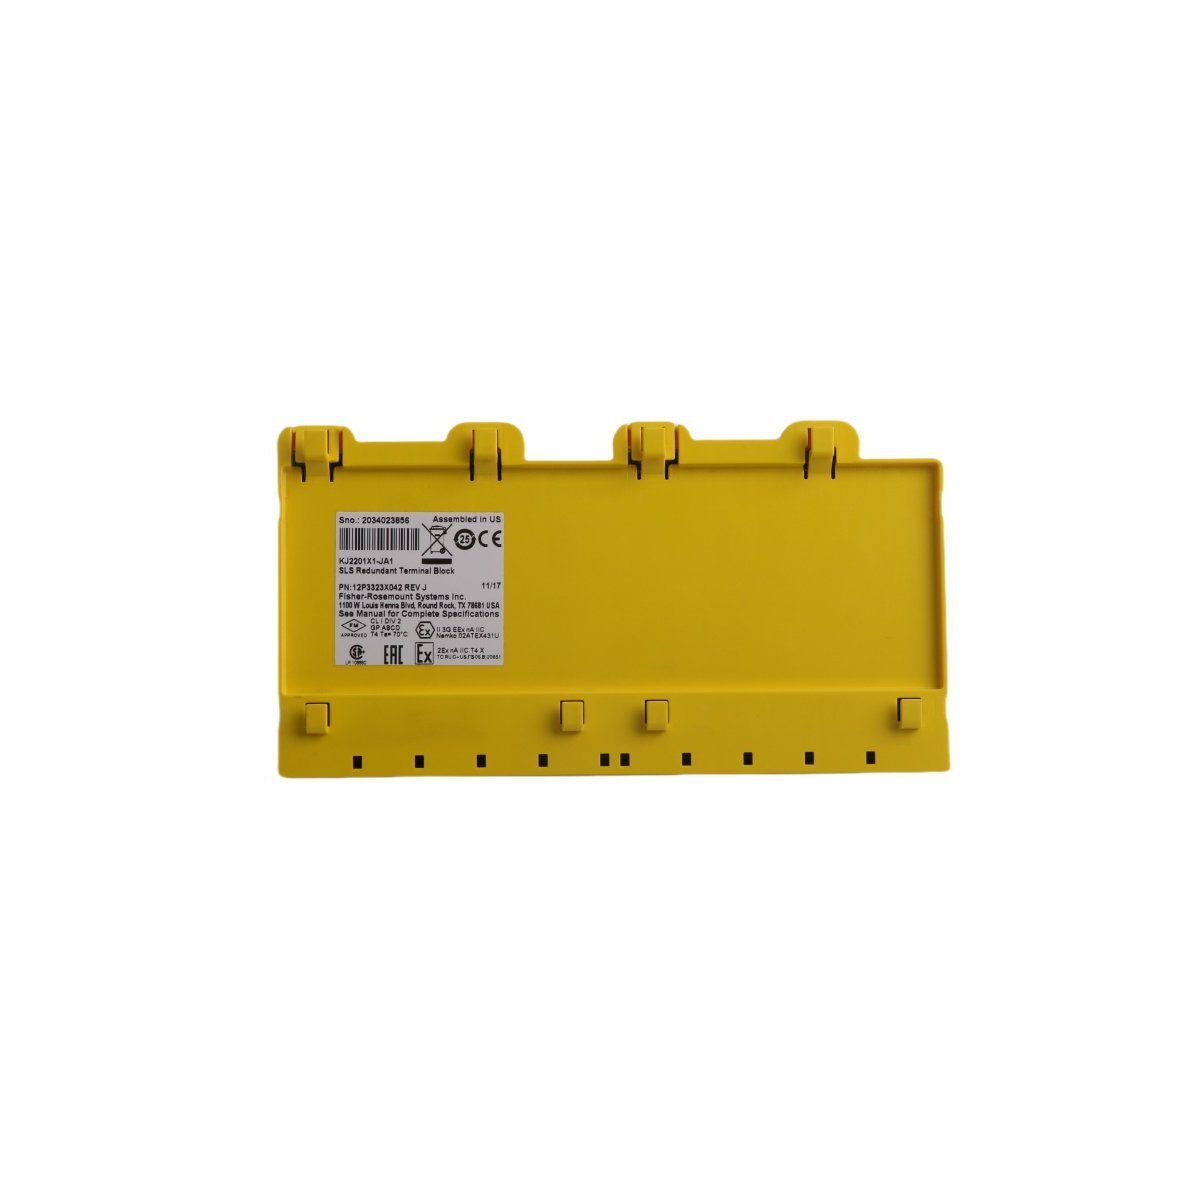
EMERSON KJ2201X1-JA1 12P3323X042 redundant terminal block. Brand New, Original Stock with Global Shipping for high-integrity safety instrumented loops.
The ABB PM864AK01 (3BSE018161R1) is a high-speed MPC862 processor unit designed for AC 800M and 800xA control systems.It features 32MB RAM, dual Ethernet ports, and supports up to 96 I/O modules, providing reliable real-time execution for demanding industrial automation tasks
We are committed to protecting your privacy. The information collected here is strictly used to provide the requested quotes, technical support, and relevant industrial automation solutions.